


Mechanica Dynamics
Telescopic Arm - Elevate X
Telescopic Arm - Elevate X
Couldn't load pickup availability
Available in Two Variants:
🔹 All Hardware (No Extrusion or 3D-Printed Parts)
Includes: Elevate X Hardware Kit
--Pivot Module sold separately--
🔹 Printed Blocks + All Hardware (No Extrusion)
Includes: Elevate X Full Kit
--Pivot Module sold separately--
MISC:
To adjust the chain length, a chain breaker is required.
You can purchase one here:
DarkSoul #25 Chain Breaker – AndyMark
Rev Gearboxes:
MAXPlanetary System Kit (9:1 Recommended)
When using a Kraken drive motor, select the 2-stage configuration with 3:1 gearing per stage, along with the corresponding 15T coupler.
Extrusion length:
Determines stroke and overall actuator length. Each stage must use the same length of extrusion.
Example: If you choose 3 ft of 1" × 1" tube, you will also need 3 ft of 1.5" × 1.5" and 2" × 2" tube.
Use the included templates to drill out the holes in the extrusion (Refer to CAD and visit "Templates" tab for a visual reference). If you purchased the "Hardware Only" kit, print out the templates and follow the instructions above.
Shafting:
3 ft of 1/2" hex shaft is sufficient to cut into axles.
Extrusions and shaft needed can be found here:
- Multipurpose 6061 Aluminum Rectangular Tube, 1/16" Wall Thickness, 1" High x 1" Wide Outside
Share


Elevate X Details
🔍 How This Actuator Stands Apart
Many teams have asked how our 2-Stage Cascading Linear Actuator compares to systems like the Swyft Ascend, Thrifty Telescoping Tube, and AndyMark’s Climber-in-a-Box. Each solution has strengths depending on the application. Here's a breakdown to help you understand where our actuator fits in:
📚 What is a Cascading Rig (Bidirectionally Driven)?
In FRC, a bidirectionally driven cascading rig is a type of telescoping elevator where each stage is mechanically linked—typically using chain, rope, or cable—so that all stages extend and retract in a synchronized, fixed ratio, and both directions are actively powered.
Unlike spring-based systems that extend passively or rely on gravity for retraction, a bidirectional cascade:
- Uses a motor and gearbox to drive both extension and retraction
- Employs chain or cable routing to maintain 1:1 or proportional motion between stages
- Provides consistent, rigid movement in any orientation, even when angled or inverted
This design makes it ideal for multi-functional mechanisms like climbing, extending arms, or manipulators that require reliable and precise motion in both directions.
🌀 Motion Mechanism
Climber-in-a-Box and Thrifty Telescoping Tube use a constant force spring for extension and a winch for retraction. These are lightweight and effective for vertical climbing but may perform inconsistently when used at an angle. They also lack bearing support at each stage, which can impact stability and smoothness when repurposed for telescoping arms.
Swyft Ascend uses a rack-and-pinion first stage and a Dyneema rope-driven second stage, configured to cascade. It’s integrated into a custom extrusion and is optimized for use in pairs for compact elevator setups. However, because the pinion is at the top, the motor and gearbox must also be mounted high, which may raise the robot’s center of gravity depending on layout.
Elevate X uses a #25 chain-driven first stage and bidirectionally driven Dyneema cascading ropes for the second stage. This setup allows the motor and gearbox to remain low-mounted, improving stability and simplifying integration into pivoting arms or custom mechanisms.
🧩 Flexibility & Integration
- Designed around standard 1” aluminum profiles, making it easy to adapt or replace components
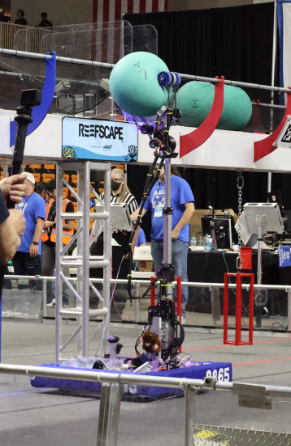
- Team 8865 successfully used Elevate X as a telescoping arm mounted on a pivot with an algae intake end effector for the 2025 Reef Scape Season
- Compatible with a pivot module, adding an extra degree of freedom for dynamic manipulators
- COTS-compliant for official FRC competitions
- Utilizes 10-32 fasteners
- Compatible with REV gearboxes & Kraken/Neo motors
- Uses PETG CF 3D-printed bearing blocks with sealed bearings
- Modular, durable, and relatively easy to assemble
- Versatile mounting options
- Designed for maximum strength with minimal weight
- Easy tensioning system allows for quick dyneema cable tensioning as needed.
⚙️ Bearing Design
While other systems may rely on bushings or individual bearings, Elevate X uses sealed bearing blocks at all major interfaces. This supports smooth, consistent extension, even under load and at non-vertical angles—making it a reliable option for demanding use cases.
For more videos/info visit these sources:
CAD Files & Documentation: Elevate X - Public
Assembly Videos: Youtube
Elevate X 2-Stage Cascading Linear Actuator © 2025 by Mechanica Dynamics © 2025 by Jaylen O'Brien is licensed under CC BY-NC-SA 4.0